Helical gear calculator
Main dimensions of a helical pair on parallel shafts. The module of the hob is the normal module; the diameters are calculated with the transverse module.
Results · helical gear
- Transverse module mt
- 2.0706 mm
- Transverse pressure angle αt
- 20.647 °
- Reference diameter d₁
- 41.411 mm
- Reference diameter d₂
- 82.822 mm
- Tip diameter da1
- 45.411 mm
- Tip diameter da2
- 86.822 mm
- Root diameter df1
- 36.411 mm
- Root diameter df2
- 77.822 mm
- Working centre distance a
- 62.117 mm
- Zero centre distance a₀
- — mm
- Working transverse pressure angle αwt
- — °
- Tip shortening k·mn
- — mm
- Gear ratio i
- 2.000
- Helix lead pz1
- 485.5 mm
- Helix lead pz2
- 971.1 mm
- Virtual tooth count zn1
- 22.01
- Virtual tooth count zn2
- 44.01
- Transverse contact ratio εα
- 1.561
- Overlap ratio εβ
- 0.824
- Total contact ratio εγ
- 2.385
- Span measurement W (pinion)
- — mm
- Span measurement W (gear)
- — mm
- Dimension over balls M (pinion)
- — mm
- Dimension over balls M (gear)
- — mm
- Tooth thickness allowances Asne / Asni (pinion)
- — mm
- W limits max / min (pinion)
- — mm
- M limits max / min (pinion)
- — mm
- Tooth thickness allowances Asne / Asni (gear)
- — mm
- W limits max / min (gear)
- — mm
- M limits max / min (gear)
- — mm
- Normal backlash jn min … max
- — mm
Results are for the initial values; they update when you change the values.
Helical gear formulas
| Quantity | Formula | Example |
|---|---|---|
| Transverse module | mt = mn / cos β | 2.0706 mm |
| Transverse pressure angle | tan αt = tan 20° / cos β | 20.647 ° |
| Reference diameter | d = mt · z | 41.411 mm |
| Tip diameter | da = d + 2 · mn | 45.411 mm |
| Root diameter | df = d − 2.5 · mn | 36.411 mm |
| Centre distance | a₀ = (d₁ + d₂) / 2 | 62.117 mm |
| Working transverse pressure angle | inv αwt = inv αt + 2(x₁ + x₂) tan αn / (z₁ + z₂) | 20.647° (x = 0) |
| Working centre distance | a = a₀ · cos αt / cos αwt | 62.117 mm |
| Shifted diameters | da = d + 2mn(1 + x − k), df = d − 2mn(1.25 − x) | 45.411 / 36.411 mm |
| Span measurement | W = [(k − 1) pbt + sbt] · cos βb | in the normal section |
| Lead | pz = π · d / tan β | 485.5 mm |
| Virtual tooth count | zn = z / (cos² βb · cos β), sin βb = sin β · cos 20° | 22.01 |
| Overlap ratio | εβ = b · sin β / (π · mn) | 0.824 |
| Dimension over balls | inv αMt = inv αt + D / (db cos βb) − π / z + st / d; M = db / cos αMt + D | on a helical gear, balls rather than pins |
| Measurement limits | W = W₀ + Asn · cos αn; M with the same ball for thickness s + Asn (Asne upper, Asni = Asne − Tsn lower allowance) | cd25 default |
| Normal backlash | jbn = jwt cos αwt cos βb, jwt = (cos αt / cos αwt) [pt − s₁ − s₂ + (d₁ + d₂)(inv αwt − inv αt)], a ± Aa | min: upper allowances, a − Aa |
What you should know
Both gears of a pair have the same helix angle and opposite hands: one right-hand, the other left-hand.
The helix lead is used when setting up the helix attachment on the machine: it is the axial length over which a tooth makes one full turn.
The virtual tooth count zn tells which spur gear the tooth behaves like for strength and undercut; the form factor and cutter number are chosen with it.
Video tip
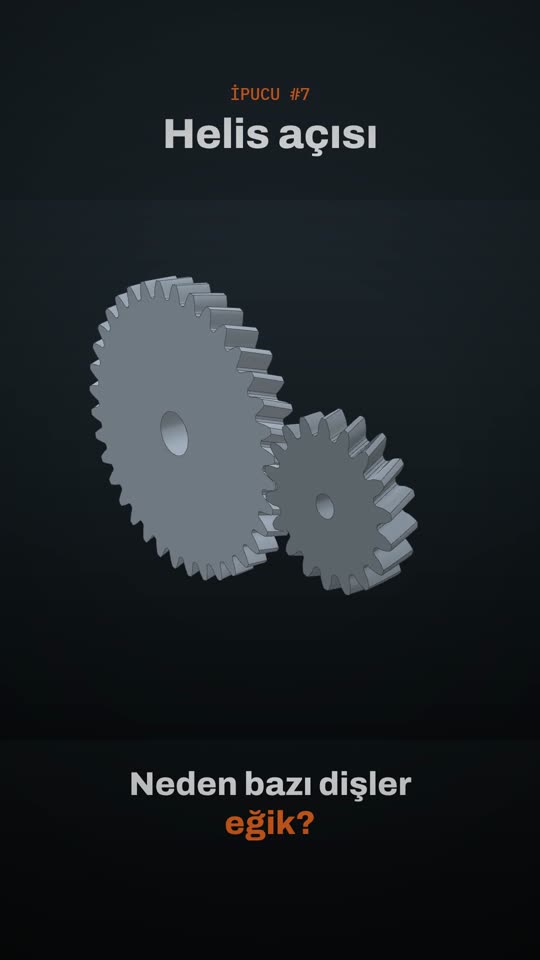
Design this gear with profile shift in the program; get undercut and interference checks, strength, technical drawing, 3D model and STEP / DXF output.
Apply for the free beta